Personal project· In progress
ROS2 Industrial Robot Cell Integration
Self-Directed Individual Project
Taking the PLC and real-hardware integration I've already done and building a ROS2 control layer on top of it.
Completed foundation
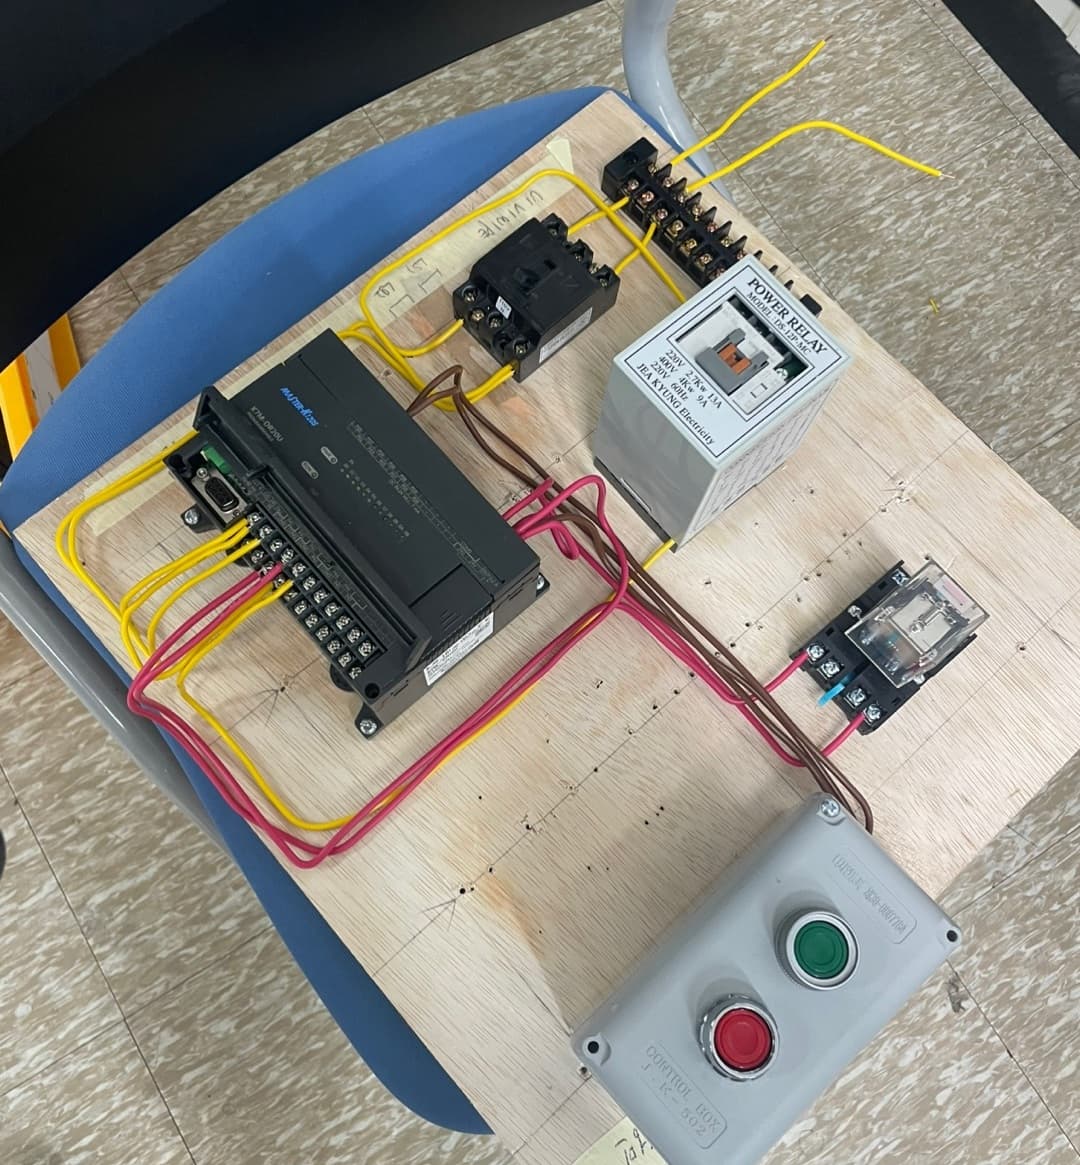
- PLC-to-Neuromeka real-hardware integration
- CC-Link handshake reasoning
- Multi-dock sequencing and servo loading-dock coordination
Planned next
- ROS2 control layer
- Orchestration and state machine
- Timeout, fault, and recovery handling
- Later perception and edge-AI integration
Contribution boundary
A solo project I started during self-study time, using the training facility's shared hardware. The ROS2 control layer and everything after it is still ahead.
Mitsubishi PLC · CC-Link · Neuromeka · Servo docks